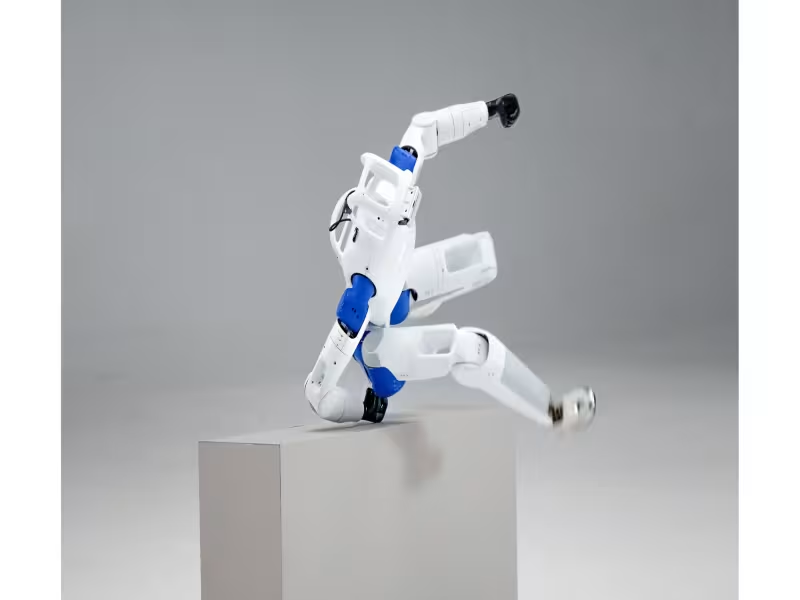
Shanghai – October 15, 2026 -- RoboParty has launched RP1 (ROBOTO 01), a humanoid robot with open access to its hardware designs, low-level drivers, control algorithms and software stack, aimed at embodied AI research. The standard version stands about 1.3 meters tall with 24 actuated degrees of freedom (DoF), while the Pro version offers 30.
RP1 opens actuator designs, firmware and control code to researchers
RoboParty is publishing the robot body design and technical resources for its in-house ROMOMO joint actuator modules, along with technical documentation and research materials. The company says the release covers mechanical structures, actuators, motion control, simulation environments, software development kits (SDKs) and training tools.
Firmware, development tools, simulation resources and robot learning frameworks are also open. RoboParty argues that closed hardware and low-level control systems limit experimental flexibility. It adds that limited visibility into a robot's internal behavior makes it hard to trace faults across model policies, control systems and hardware execution.
Pro version adds a 2-DoF neck and two 7-DoF arms for 30 actuated DoF
The standard RP1 targets research into gait, balance control and sim-to-real transfer. The Pro version adds a 2-DoF neck and two 7-DoF arms, aimed at end-to-end policies, human-robot interaction and data collection. Both DoF counts exclude the dexterous hands.
Interchangeable head modules and wrist end effectors support multiple configurations, including RoboParty's RP Hand dexterous hand. Teams can start with bipedal locomotion and later add perception, data collection or manipulation setups on the same platform. Researchers can also compare control methods on identical hardware, or hold the control method fixed and vary the hardware configuration.
RP1 ships with walking, fall recovery and whole-body control tools
The robot already supports continuous walking, recovery from external disturbances, getting up after a fall and human motion tracking. RoboParty says this reduces the need for teams to rebuild low-level motor skills before working on higher-level policies.
For whole-body intelligence work, RP1 includes whole-body control (WBC) coordinating arms, torso and legs. Supporting tools cover virtual reality (VR) teleoperation, data collection and playback, and motion retargeting. The platform integrates with RoboParty's PartyOS embodied AI system, the UFO unsupervised reinforcement learning framework and MimicLite motion imitation technology.
The open toolchain spans data collection, simulation training, deployment on physical robots and experimental validation. RoboParty says improvements to the mechanical structure, ROMOMO actuators and manufacturing quality management are meant to improve consistency in physical response and reliability. The aim is to limit hardware variation in repeated training and validation runs.
RPO project drew more than 2,600 GitHub stars after January launch
RoboParty launched the RPO open-source project in January 2026, releasing mechanical and electrical design resources plus training and deployment materials. The project has gathered more than 2,600 GitHub stars.
"We want to open up more than code," said Yi Huang, founder of RoboParty, adding that more teams innovating on a shared technical foundation would move the industry forward.