RoboParty Debuts Open-Source Humanoid RP1 With 160 N·m Joint Torque
Image
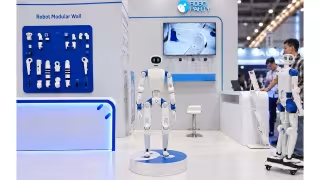
Pittsburgh – October 03, 2026 -- RoboParty unveiled RP1 (ROBOTO 01), a bipedal humanoid robot it calls the world's first high-performance full-stack open-source humanoid, at IROS 2026 on September 28. The robot delivers peak joint torque of up to 160 N·m, powered by in-house Romomo actuator modules and a real-time motion-control system.
RP1 extends RoboParty's open-source RPO project, which drew over 2,500 GitHub stars since January 2026
RP1 builds on RPO (ROBOTO ORIGIN), RoboParty's fully open-source humanoid initiative launched in January 2026. The project has attracted more than 2,500 GitHub stars and is backed by a developer community exceeding 5,000 members globally.