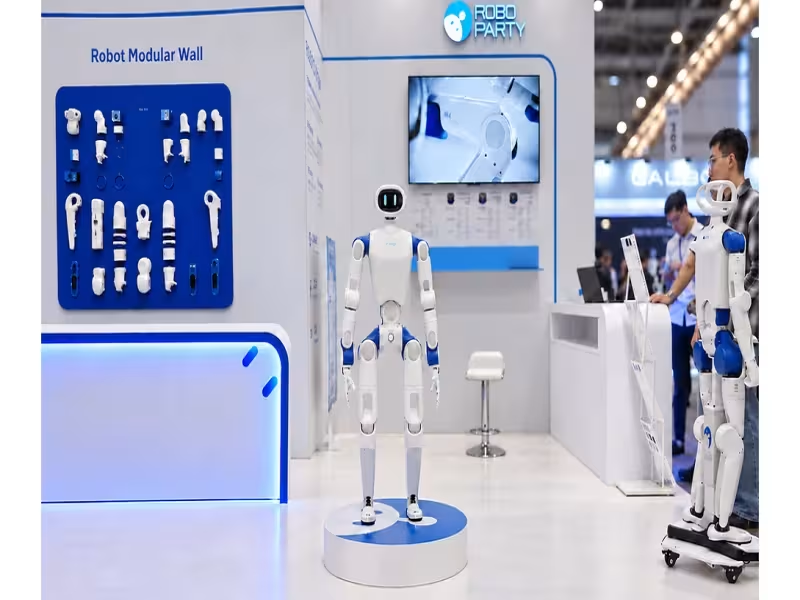
Pittsburgh – October 03, 2026 -- RoboParty unveiled RP1 (ROBOTO 01), a bipedal humanoid robot it calls the world's first high-performance full-stack open-source humanoid, at IROS 2026 on September 28. The robot delivers peak joint torque of up to 160 N·m, powered by in-house Romomo actuator modules and a real-time motion-control system.
RP1 extends RoboParty's open-source RPO project, which drew over 2,500 GitHub stars since January 2026
RP1 builds on RPO (ROBOTO ORIGIN), RoboParty's fully open-source humanoid initiative launched in January 2026. The project has attracted more than 2,500 GitHub stars and is backed by a developer community exceeding 5,000 members globally.
Live 'Kick Me' demo at IROS tested RP1's balance recovery under physical disturbance
At its IROS booth, RoboParty ran a "Kick Me" demonstration allowing attendees to push and kick RP1 directly. The robot adjusted posture and recovered balance in real time, a stress test of dynamic stability and system-level robustness. The capability is driven by PartyOS, RoboParty's open R&D foundation, which includes UFO, a training framework using unsupervised reinforcement learning to discover motor skills -- including disturbance and fall recovery -- without predefined motion trajectories.
RoboParty plans to progressively open motion-control systems, simulation tools and SDKs
The company defines "full-stack open source" beyond releasing mechanical files, committing to open its motion-control systems, simulation environments, SDKs, training tools and the PartyOS foundation itself. This would let external developers participate across the stack, from hardware and low-level control through model training and deployment.
"We want RP1 to become an open foundation that developers can access, modify, train and continuously improve,